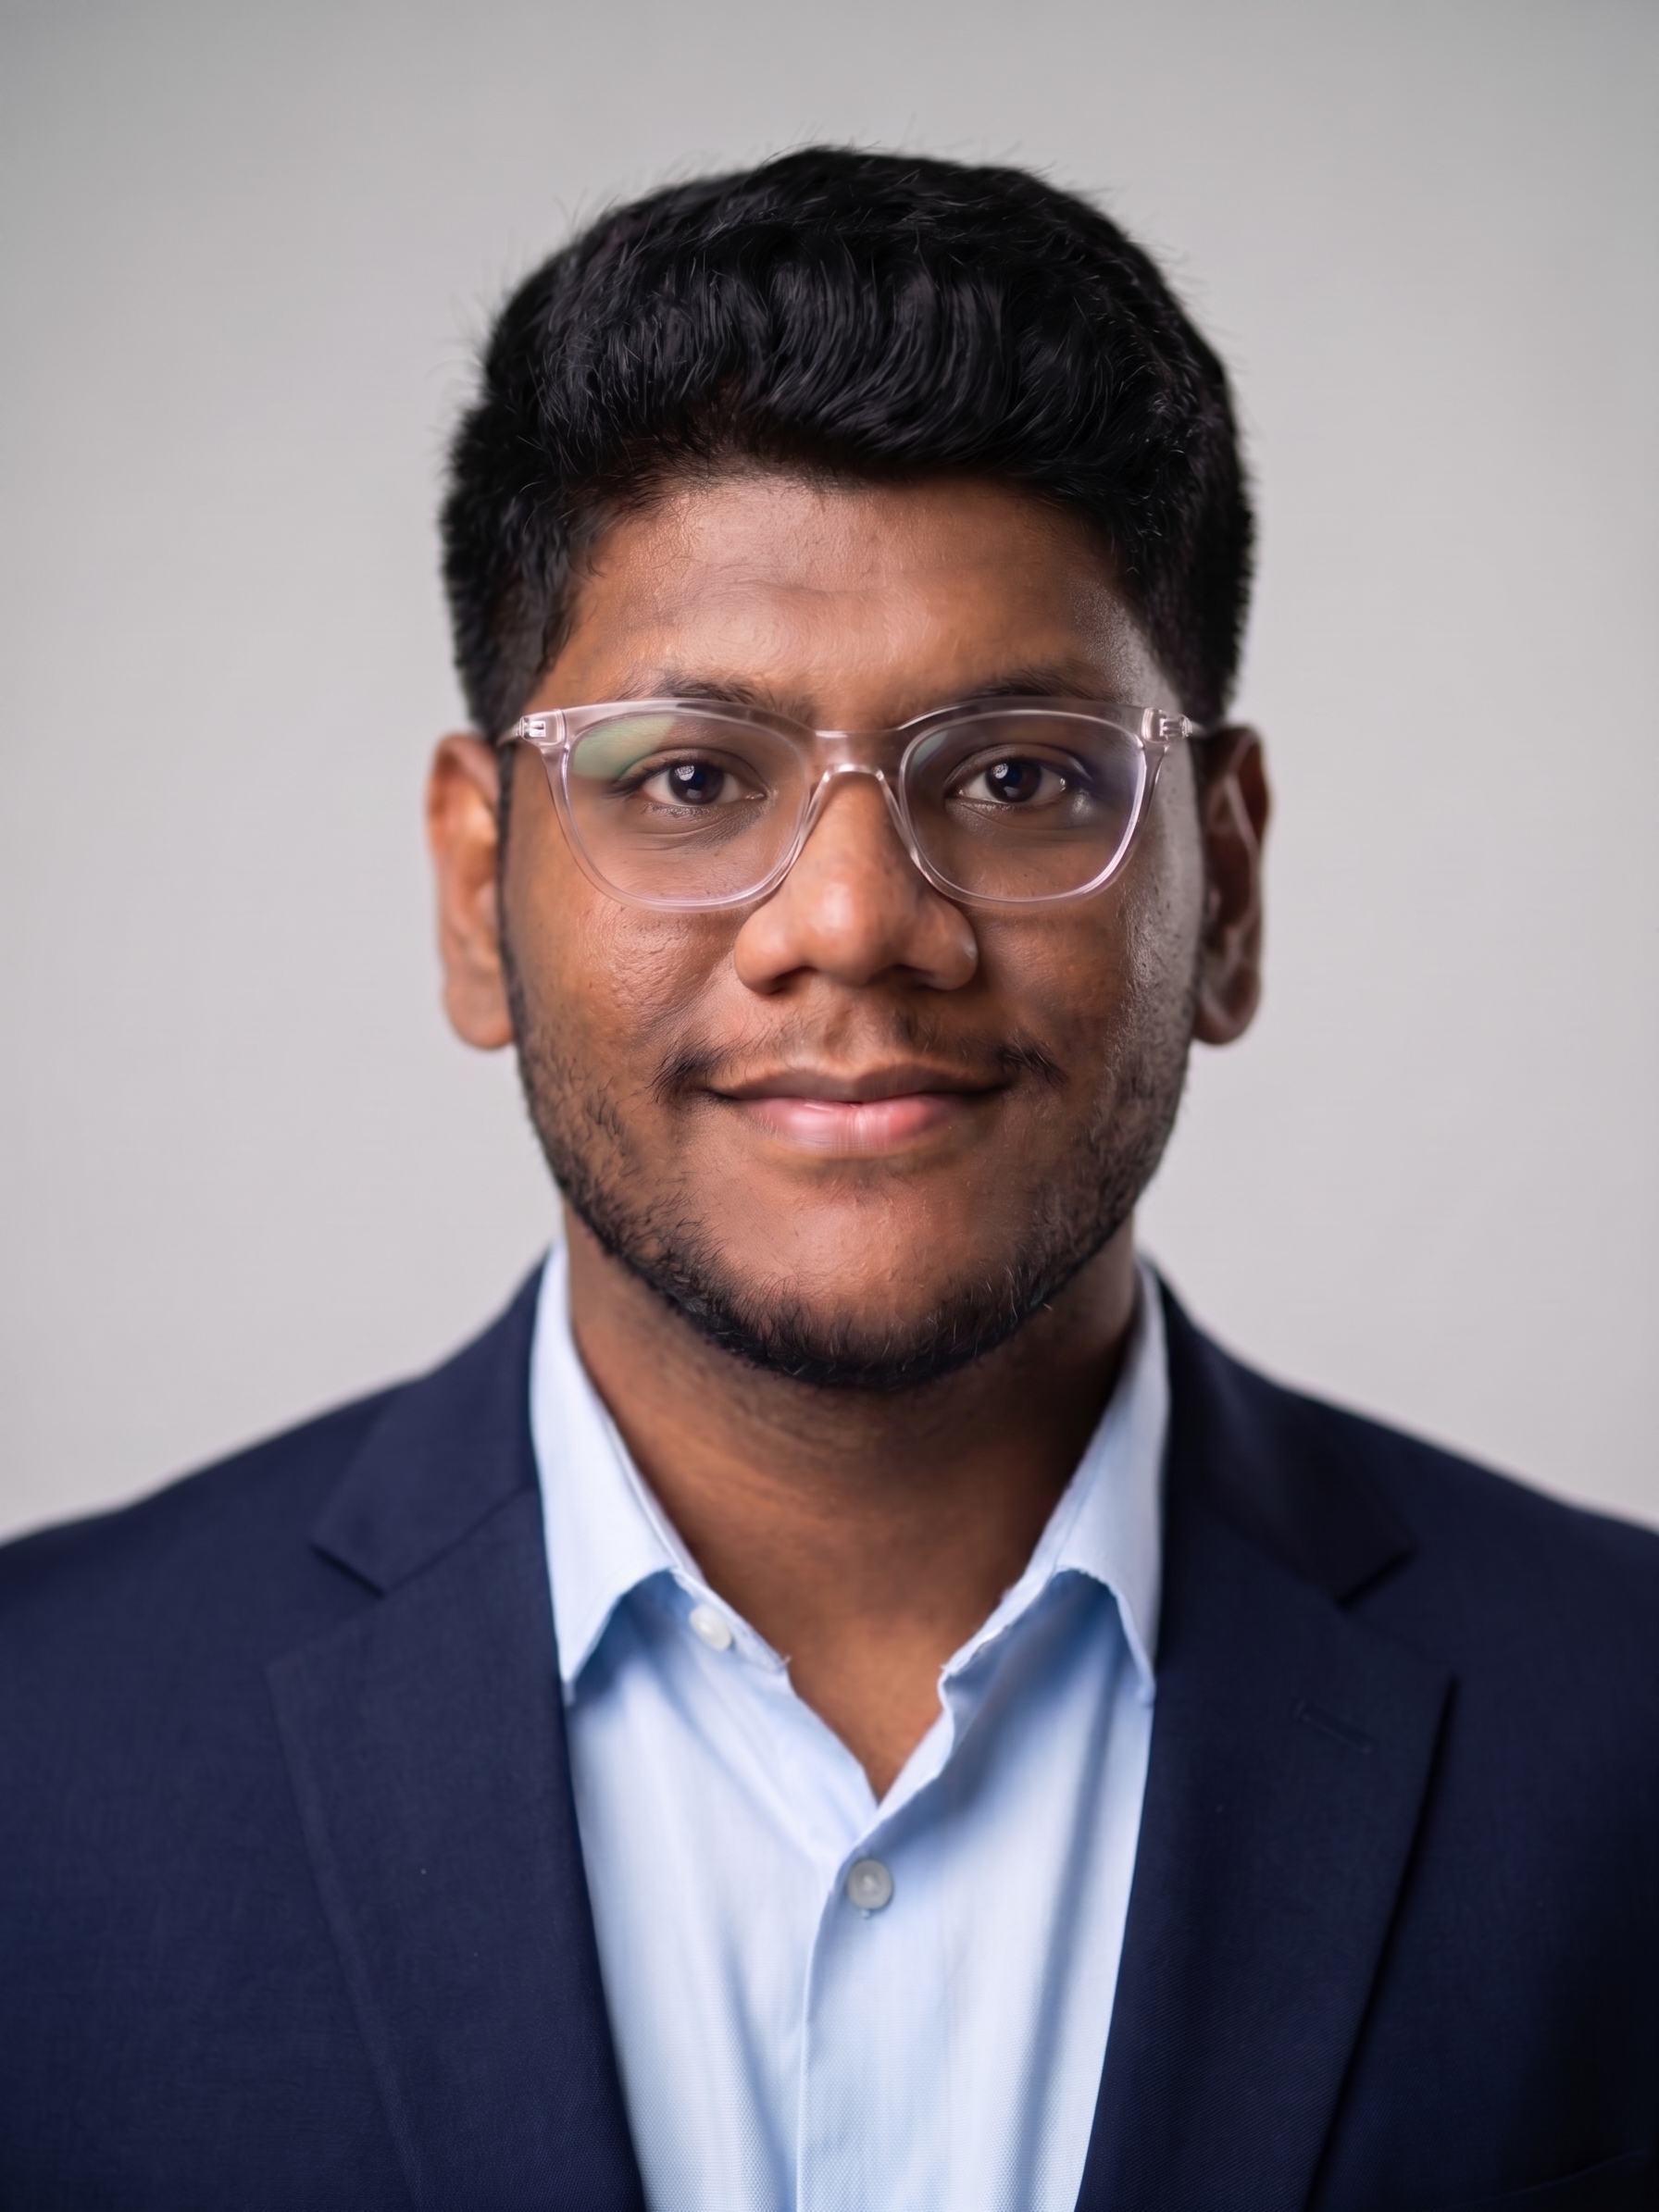
Vijay Shankaran Vivekanand
Embodied AI | Robot Perception | Adaptive Control
Focused on the intersection of deep learning and robust control theory for autonomous robotic systems. Developing data-efficient learning algorithms for perception-action loops, specifically leveraging event-based vision and foundation models to enable real-time decision-making in dynamic, unstructured environments.
About & Research Focus
Core Research Pillars
Education
Publications
5 Peer-Reviewed Articles (Frontiers, IEEE, ACM)Toward autonomous event-based sensorimotor control with supervised gait learning and obstacle avoidance for robot navigation
Miniature robots are useful during disaster response and accessing remote or unsafe areas. They need to navigate uneven terrains without supervision and under severe resource constraints such as limited compute, storage and power budget. Event-based sensorimotor control in edge robotics has potential to enable fully autonomous and adaptive robot navigation systems capable of responding to environmental fluctuations by learning new types of motion and real-time decision making to avoid obstacles. This work presents a novel bio-inspired framework with a hierarchical control system to address these limitations, utilizing a tunable multi-layer neural network with a hardware-friendly Central Pattern Generator (CPG) as the core coordinator to govern the precise timing of periodic motion. Autonomous operation is managed by a Dynamic State Machine (DSM) at the top of the hierarchy, providing the necessary adaptability to handle environmental challenges such as obstacles or uneven terrain. The multi-layer neural network uses a nonlinear neuron model which employs mixed feedback at multiple timescales to produce rhythmic patterns of bursting events to control the motors. A comprehensive study of the architecture's building blocks is presented along with a detailed analysis of network equations. Finally, we demonstrate the proposed framework on the Petoi robot, which can autonomously learn walk and crawl gaits using supervised Spike-Time Dependent Plasticity (STDP) learning algorithm, transition between the learned gaits stored as new states, through the DSM for real-time obstacle avoidance. Measured results of the system performance are summarized and compared with other works to highlight our unique contributions.
Dynamic Neural Fields Accelerator Design for a Millimeter-Scale Tracking System
Robot Locomotion through Tunable Bursting Rhythms using Efficient Bio-mimetic Neural Networks on Loihi and Arduino Platforms
Frame of Events: A Low-latency Resource-efficient Approach for Stereo Depth Maps
Robot Locomotion Control Using Central Pattern Generator with Non-linear Bio-mimetic Neurons
Experience
Industry Engineering & Laboratory Research Track RecordIndependently architected an asynchronous, high-throughput data pipeline for the real-time ingestion of smart meter telemetry. Optimized the system for concurrency to handle massive data streams, reducing data availability latency and directly supporting the training of downstream forecasting models.
Architected a domain-specific Retrieval-Augmented Generation (RAG) system using Gemini 2.5 on GCP. Engineered the vector retrieval pipeline for curated technical documentation, significantly reducing query latency for customer support.
Developed comparative models (Prophet vs. XGBoost) for energy load forecasting, achieving 92% accuracy in predicting consumption peaks for commercial clients.
Designed automated control logic for remote generator operations, increasing system response reliability by 80% during critical grid demand events.
Featured Systems Projects
Hardware Neuromorphic Architectures & Robust Control TheoryPitwall: Trustable AI Racing Coach
A split-brain embodied AI racing coach proven at 130 mph at Sonoma Raceway. Combines an ultra-low-latency reflexive hot path (Gemma 4 on Pixel 10 TPU, <50ms) with a strategic warm path (Gemini 3.0 on Vertex AI, 2-5s) over 5G using Antigravity store-and-forward telemetry pipelines.
Autonomous Event-Based Sensorimotor Control & Supervised Gait Learning
Bio-inspired hierarchical control system for quadruped robots featuring a multi-layer neural network with hardware-friendly Central Pattern Generators (CPG) and a Dynamic State Machine (DSM). Autonomously learns walk and crawl gaits using supervised Spike-Timing Dependent Plasticity (STDP) for real-time obstacle avoidance.
28-nm DNF Hardware Accelerator for Millimeter-Scale DVS Tracking
A compact-size 28-nm CMOS hardware accelerator for Dynamic Neural Fields (DNF) executing millimeter-scale object tracking on asynchronous Dynamic Vision Sensor (DVS) streams.
Tunable Bursting CPG Locomotion on Intel Loihi & Arduino
Designed and deployed tunable bursting Central Pattern Generators (CPGs) for quadruped locomotion across standard microcontroller (Arduino) and fully asynchronous neuromorphic (Intel Loihi) architectures.
Frame of Events Low-Latency Stereo Depth Mapping for DVS
Hybrid temporal-contrast event sensor pipeline generating 'frame of events' for high-speed robotic stereo disparity and depth estimation in resource-constrained environments.
Binaural Neuromorphic Silicon Cochlea Simulation & ITD Sound Localization
Software simulation modeling a mixed-signal silicon cochlea front-end coupled with an asynchronous Spiking Neural Network on Intel Loihi. Replicates human auditory periphery mechanics to perform sound localization via sub-microsecond Interaural Time Difference (ITD) detection.
Chaotic Neural Network (CNN) Image & Data Encryption
Designed a high-security cryptographic framework leveraging Chaotic Neural Networks where network weights and biases are driven by deterministic chaotic sequence generators for high-entropy image diffusion and bit-level permutation.
LQR & Model Predictive Control for Nonlinear Inverted Pendulum on Cart
Formulated adaptive state-space stabilization, swing-up trajectory optimization, and robust disturbance rejection for a classic underactuated nonlinear robotic mechanism.
Cover-Based Image Steganography Using DCGANs
End-to-end cover-based steganography framework utilizing Deep Convolutional Generative Adversarial Networks (DCGAN), Dense Encoders, and Reed-Solomon error correction to conceal arbitrary secret data payloads inside synthesized cover images without perceptual visual distortion.
Technical Skills & Toolchains
Machine Learning, Neuromorphic Hardware, Control Theory & CloudAI & Machine Learning
Robotics & Control
Hardware & Embedded
Languages & Tools
Honors & Community Leadership
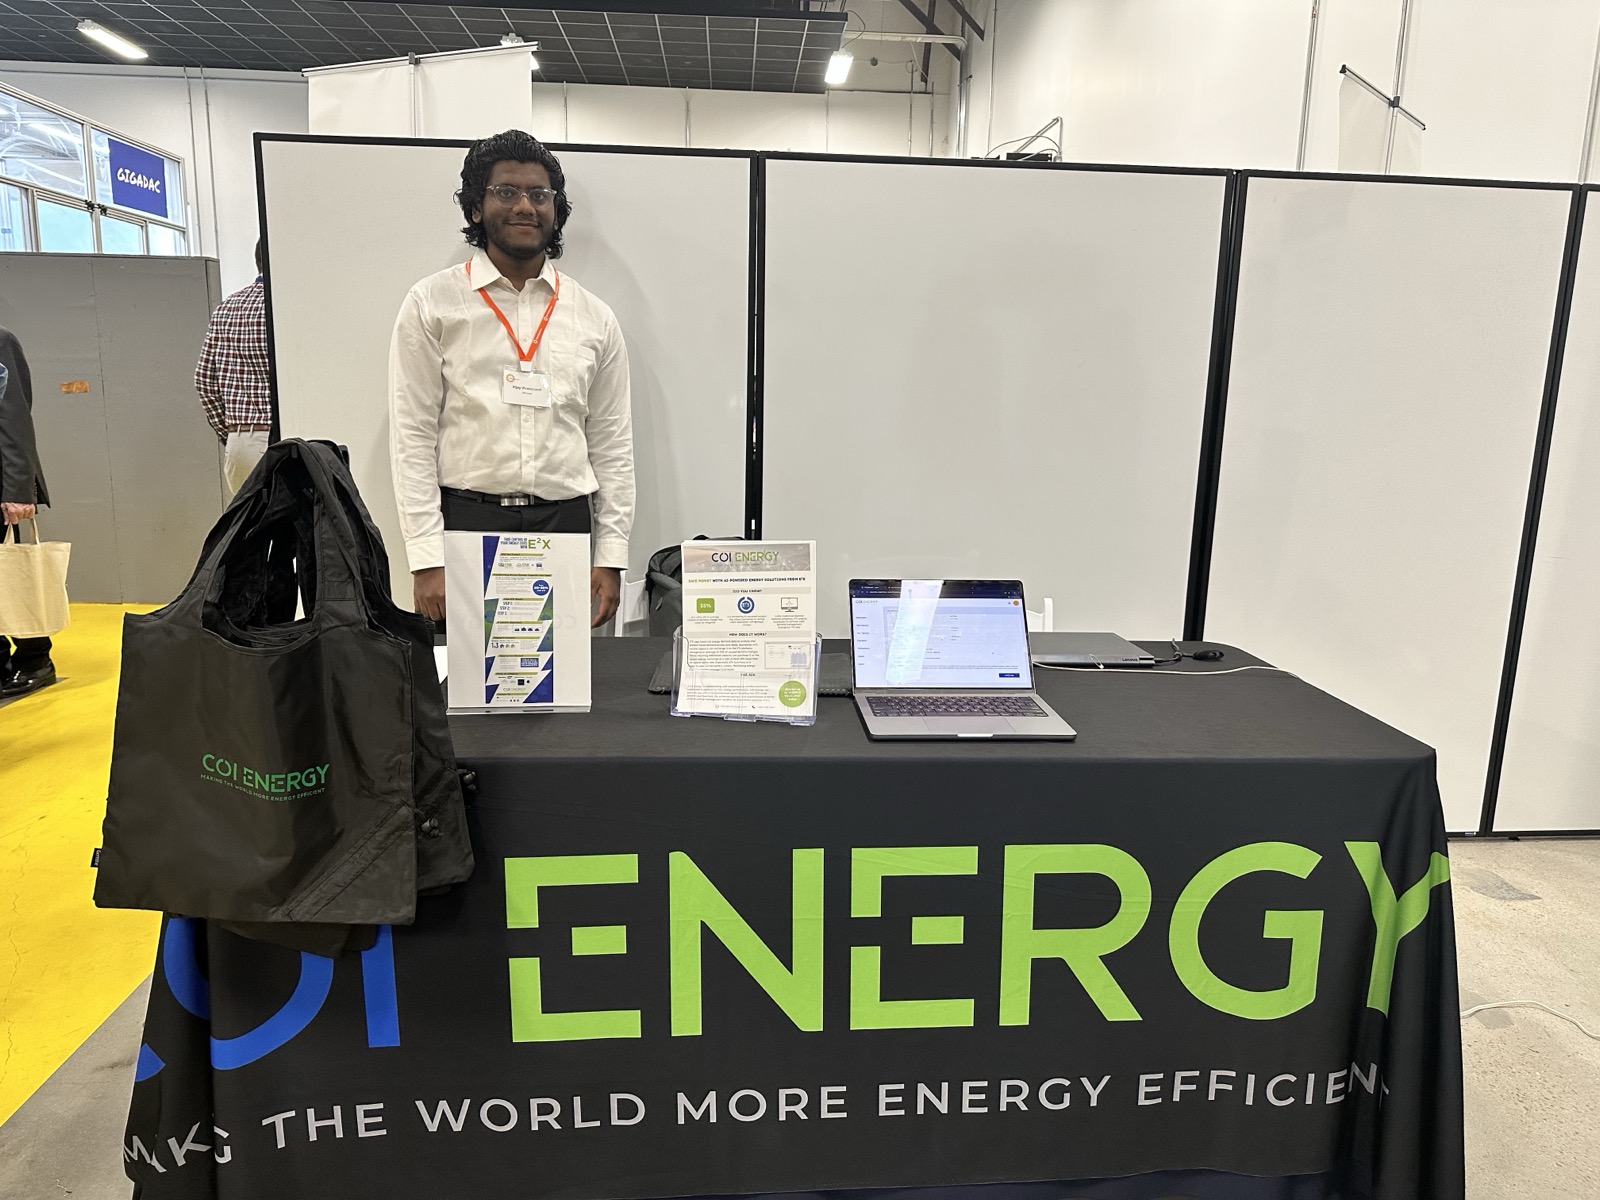
Recognitions across venture showcases, academic scholarships & mentorshipSelected as the finalist presenter for COI Energy at the prestigious TechCrunch Disrupt Finals.
Awarded for exceptional engineering contributions and high-impact infrastructure delivery, chosen via company-wide vote.
Merit-based scholarship awarded for maintaining top-tier academic standing throughout the undergraduate program.
Competed in nationwide robotics competition focused on building autonomous robotics solutions, placing in the top tier among thousands of teams.
Personality & Passions
When I am not training neural networks, tuning Kalman filters, or wiring neuromorphic testbenches, you'll find me conquering Destiny 2 raids, editing cinematic video cuts, drawing digital art, cheering during football matchdays, and cracking complex strategy puzzles.
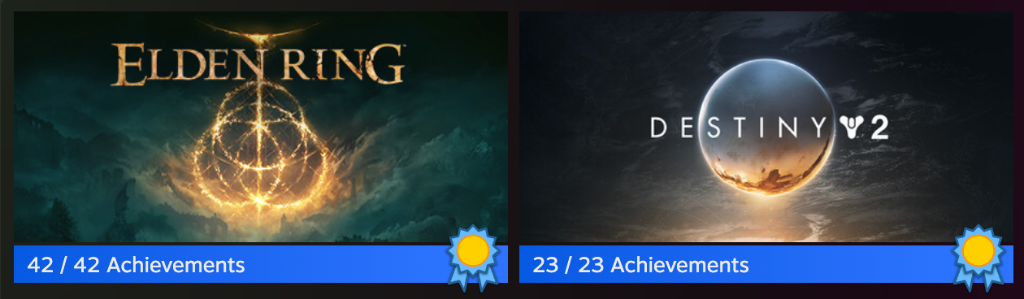
Video Games: Destiny 2 & Elden Ring
Massive fan of rich lore, precision mechanics, and coordinated gameplay. Achieved 100% Steam completion across both Elden Ring (42/42) and Destiny 2 (23/23). Whether executing flawless endgame raid mechanics or mastering dodge timings in The Lands Between, gaming is where tactical reflexes meet deep narrative world-building.
Cinematic Video Editing & Motion
Crafting narratives through visual rhythm and acoustic tempo. Blending sound design with frame-accurate cuts, dynamic transitions, and color grading to transform raw sequences into impactful visual stories.
Digital Art & Scientific Illustration
Exploring creative expression on digital canvas—designing biological/robotic system architectures, neural network flowcharts, character concepts, and spatial diagrams.
Football / Soccer
Enthusiastic player and follower of football. Enjoy playing weekend pickup games, following league and Champions League matches, and analyzing team tactics and formations.
Chess, Puzzles & Strategy
Enjoy playing chess, solving mechanical and logic puzzles, and exploring strategy games that involve multi-step planning and analytical problem solving.
Life Outside the Lab
01 / 08Candid moments, campus life, scenic trails, and travel chronicles captured along the way.
“In robotics as in life: before you can make decisive, optimal decisions, you must build high-fidelity internal models of the world.”
“The highest form of engineering is taking immense systemic complexity and distilling it into an intuitive, elegant interface.”
“A closed-loop system with tight feedback always outperforms an open-loop giant with perfect initial calibration.”
Let's Build the Future of Robotics & AI
Interested in collaborating on embodied intelligence, neuromorphic architectures, or autonomous systems?